Published : 20 Oct 2026, 02:47 PM
Updated : 20 Oct 2026, 02:47 PM


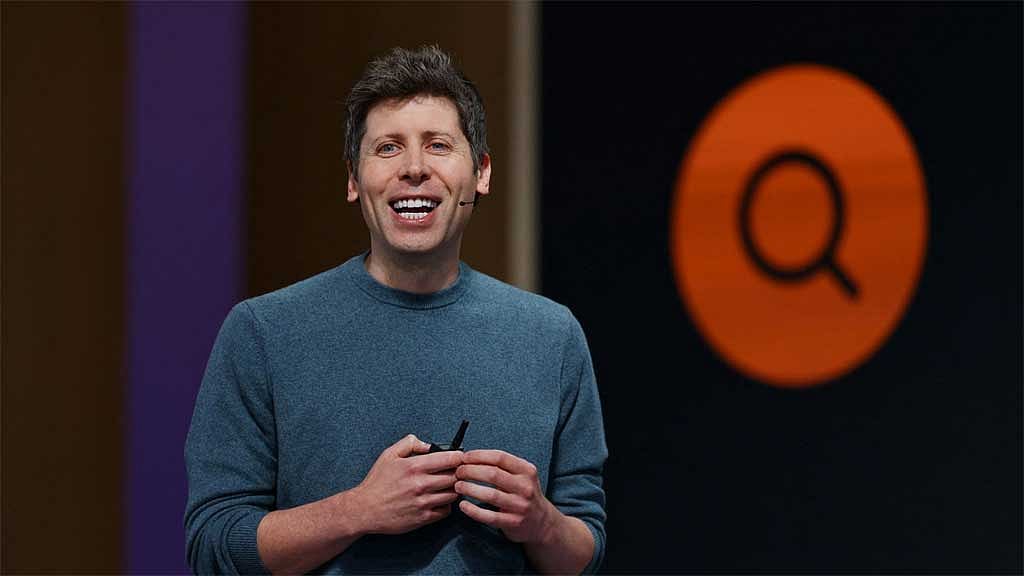
OpenAI is developing a humanoid robot, with Chief Executive Sam Altman teasing a public demonstration as early as 2027, India Today reports.
Altman confirmed the plans in appearances on the Sources podcast and in comments to Fortune magazine, arguing that a human-shaped robot was the most practical form factor for a world built around people. “The world is very much designed for people,” he said. “Matching that form factor seems good.”
But Altman cautioned against expecting rapid results. “I think we’ll have a cool demo in 2027,” he said, while adding that humanoid robots were unlikely to become a common sight on streets for several more years, India Today reported.
The OpenAI CEO declined to share details about the robot’s physical design, saying that was “less important than really figuring out the brain that makes the robot work” — referring to the AI models that process sensor and camera data to plan and carry out movements.
OpenAI reportedly set up a dedicated humanoid robotics lab last year and currently has 27 open robotics vacancies covering areas including motion control, whole-robot behaviour, and hardware manufacturing at scale.
The announcement comes as competition in the humanoid space intensifies, particularly from Chinese firms. Unitree has broken sprinting records with its robots, while Xpeng recently demonstrated its IRON humanoid walking off a production line under its own power. Tesla has also been developing its Optimus robot for years.
OpenAI’s foray into robotics builds on its earlier Dactyl research project, which trained a robotic hand using simulation to manipulate physical objects, including solving a Rubik’s Cube.